Request data →

Robotics training data

Robots don't get a 90% chance.

Ninescale AI records, simulates and labels the data that takes robots from 90% to 99.9999% reliable.

01 / The gapReliability
90%

At 90% reliable,
10 in 100 fail.

Good enough for a demo. Not good enough for a robot working next to people.

Today · clinical lab intake

Every sample is still sorted by hand.

Rack after rack, one tube at a time. It's exactly the work robots should take over — and the data they need to learn it.

Real footage · clinical lab, Feb 2026Faces blurred
02 / What we sell

The data robots learn trust from.

01

Recorded

Real people, real homes, real factories. Egocentric and teleoperated footage captured to spec, with hand pose, depth and multi-view on request.

  • Egocentric
  • Teleop
  • Multi-view
02

Simulated

Scenario-matched simulation that fills the long tail — the rare drops, slips and edge cases you can't wait to film in the real world.

  • Long-tail
  • Domain-randomised
  • Paired with real
03

Labelled

Every frame passes through LabelNow: segment boundaries, success / failure, rewards and QA by trained reviewers before it ships.

  • Segments
  • Rewards
  • Human QA
03 / From LabelNow

Real and simulated.
Side by side.

A

Recorded

Captured by real people on real tasks, then segmented and scored in LabelNow.

REC · 01
Place tubes into test-tube rack

Sample rack loading

Modality
Handheld gripper · RGB + 6-DoF pose
Frames
1,646 frames
REC · 02
Move sample tubes tray to tray

Blood tube transfer

Modality
Handheld gripper · RGB + 6-DoF pose
Frames
2,693 frames
REC · 03
Transfer capped vials

Vial handling

Modality
Handheld gripper · RGB + 6-DoF pose
Frames
2,864 frames
REC · 04
Grasp and lift sample tubes

Lab tube pick

Modality
Handheld gripper · RGB + 6-DoF pose
Frames
2,493 frames
B

Simulated

The same tasks rebuilt in simulation — with the edge cases reality rarely films.

SIM · 01
Conveyor pick into target bin

Tube to bin

Modality
Sim · RGB + actions
Frames
3,178 frames
SIM · 02
Place parts onto cups

Cup stacking

Modality
Sim · RGB + actions
Frames
5,906 frames
SIM · 03
Track bins as they move

Bin shuffle

Modality
Sim · RGB + actions
Frames
3,161 frames
SIM · 04
Drop parts onto rings

Ring placement

Modality
Sim · RGB + actions
Frames
1,789 frames

Same episode. Two worlds.

A real robot episode rebuilt end to end — Gaussian-splat background, generated object meshes, MuJoCo physics. Drag the seam.

● Real robotSimulation ○
⟷
AUTOLab · Block into cupSource: public DROID episodes
04 / Real2Sim

Captured once. Rebuilt in physics.

Every capture is recorded so it can become a simulation environment — the same scene, the same camera, real contact physics.

Contact-driven physicsBlock lifted 12.6 cm · no scripting
Novel views of the scene360° fly-through of a rebuilt DROID scene

0.6 mm

Median depth error on the best rebuilt object

5 / 5

±2 mm perturbation trials passed

0

Unintended contacts while lifting by physics alone

Sim → Real

Trained in simulation.
Works on the real robot.

0

Real-world training data · the policy learned only in simulation
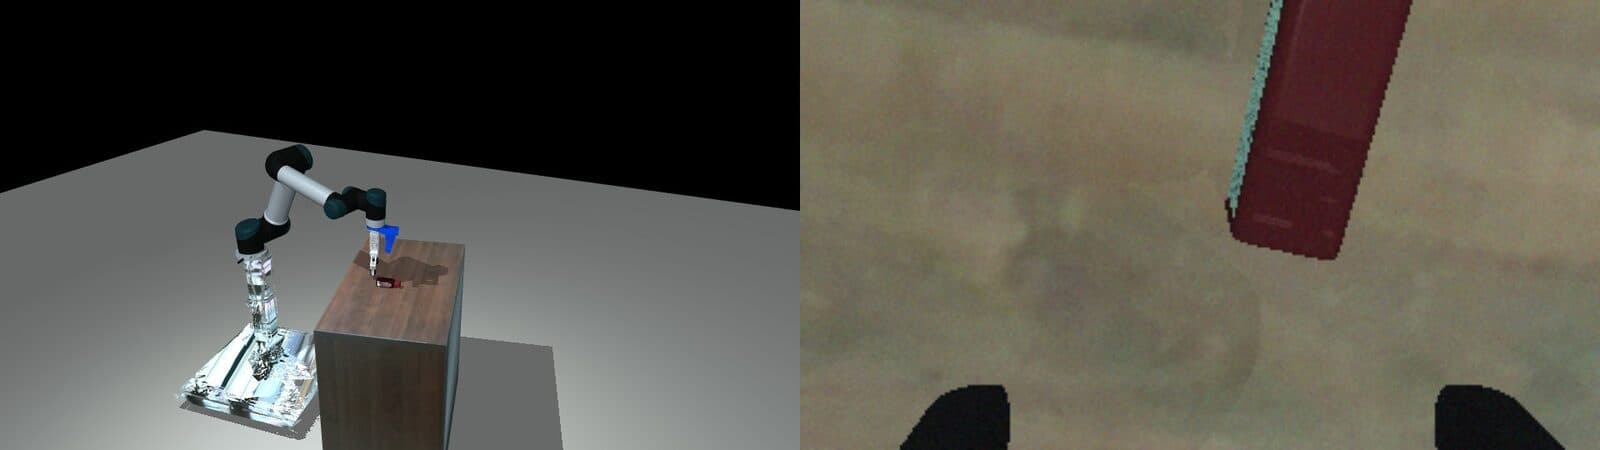
UR5 bottle pick in simulation, with the simulated wrist camera view
Simulation · virtual lab and the wrist camera the policy sees
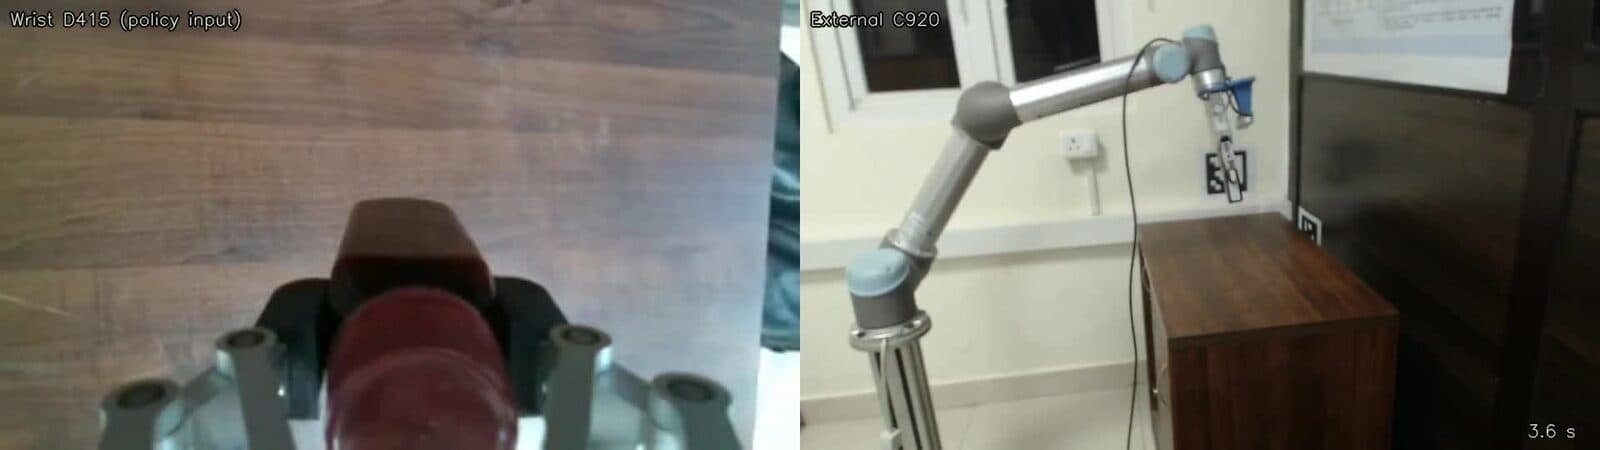
Real UR5 robot picking a bottle, wrist camera and external view
Real robot · same policy, wrist camera as its only input
05 / Pipeline

From capture
to checkpoint.

One pipeline, built on LabelNow, that turns raw human activity into training-ready robot data.
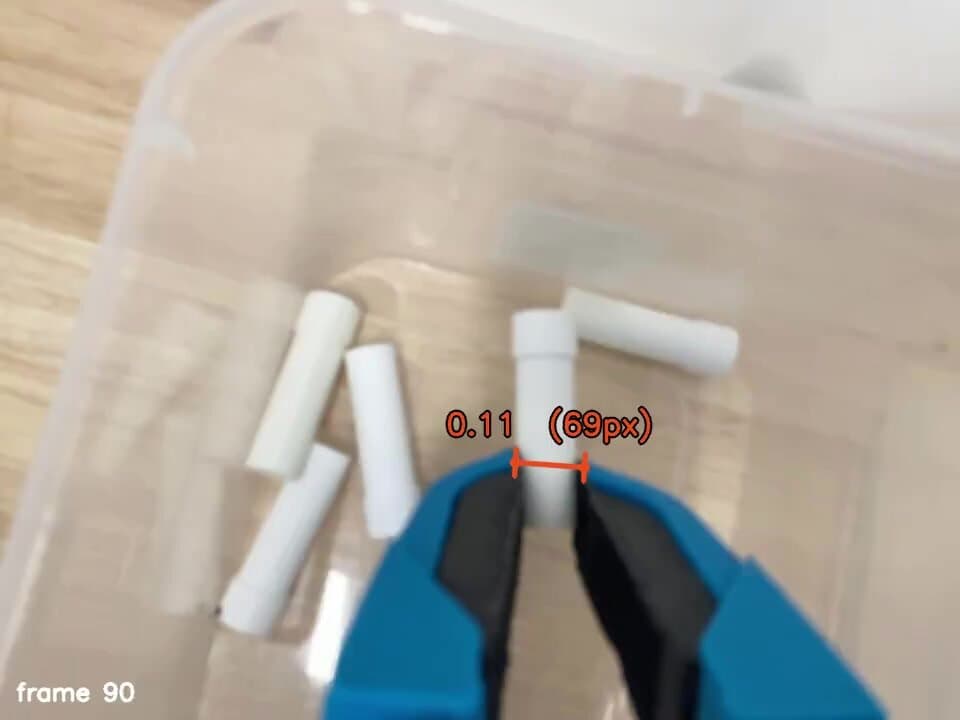
Handheld gripper closing on a tube, with jaw width measured on the frame
Grasp events labelled automatically from jaw width + camera pose
  1. 01 — CAPTURE

    Capture

    A distributed contributor network records tasks to your spec on phones and rigs.

  2. 02 — SIMULATE

    Simulate

    We mirror each real task in simulation and generate the variations reality can't.

  3. 03 — LABEL

    Label

    LabelNow annotates segments, outcomes and rewards — frame by frame.

  4. 04 — VERIFY

    Verify

    Multi-pass human QA with agreement scoring. Bad frames never ship.

  5. 05 — DELIVER

    Deliver

    Training-ready datasets in your format: RLDS, LeRobot, HDF5 or raw.

99.9%

Expert policy success in simulation

96%

Sim success after scaling up

21,504

Simulated robots practising at once

173M

Practice steps per experiment

06 / Contact

Add a nine.

Tell us the task. We'll send back a sample dataset.

Interested in